My research focuses on embodied intelligence for robot locomotion. I am interested in how robots move in complex environments (e.g., rubble, leaf litter, and sand).
I work on dynamic modeling and model-based control, and I also study learning-based control to improve performance with data and experience.
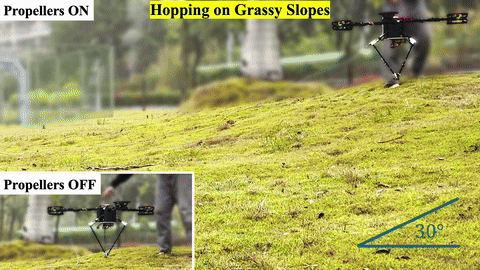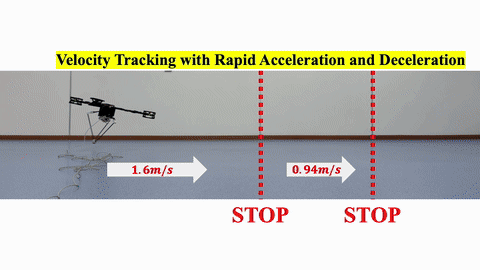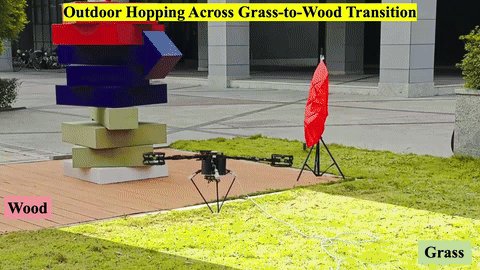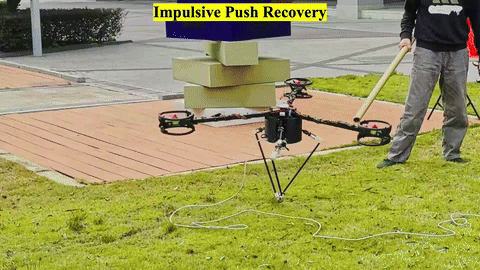
Propeller-Assisted 3D Hopper: Hierarchical Force Allocation
Research Assistant @ CUHK · Jul 2025 – Jun 2026
Developed an SRB-based Hierarchical Force Allocation (HFA) stack for a 3-RSR parallel-leg hopper, prioritizing leg contact forces and using tri-rotor thrust as residual authority. Built the real-time LCM control middleware and inverse-kinematics pipeline, enabling continuous 3D hopping and outdoor disturbance recovery.
* First-authored paper accepted by IEEE CASE 2026 (Best Student Paper Award Finalist).
Hopping Mobile Manipulation
Research Assistant @ CUHK · 2025 – Present
Details will be posted here after the paper is published.
Co-Designing towards Deployable Hopping: An LLM Shapes a Hopper's Leg and Rotors
CoRL 2026 Workshop
An LLM co-designs the leg and rotors of a propeller-assisted hopper in a simulator grounded in the real Pro-OMEGA2, whose closed-chain 3-RSR leg is validated against its logs (7.3 mm error). The LLM never proposes an unbuildable design, and its best design, four rotors on Pro-OMEGA2's leg, hops faster and steadier than the original.
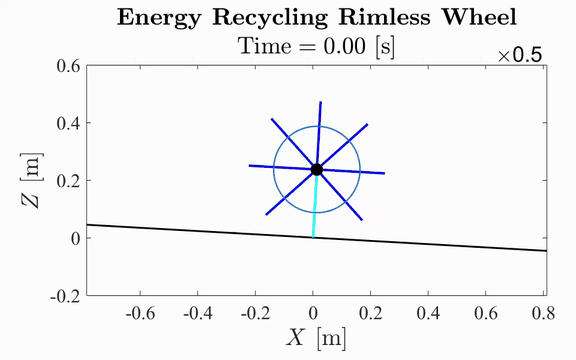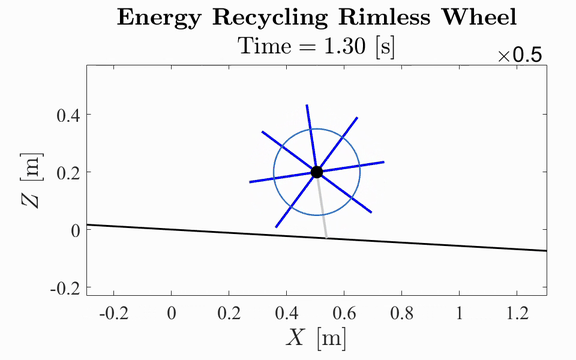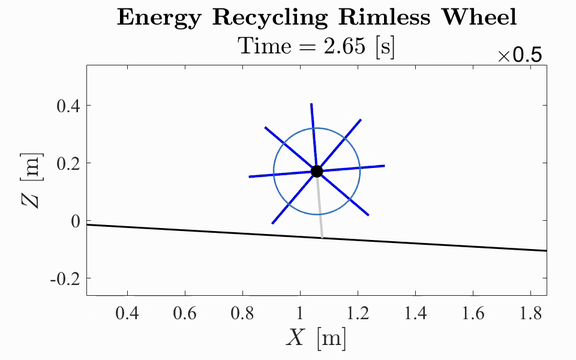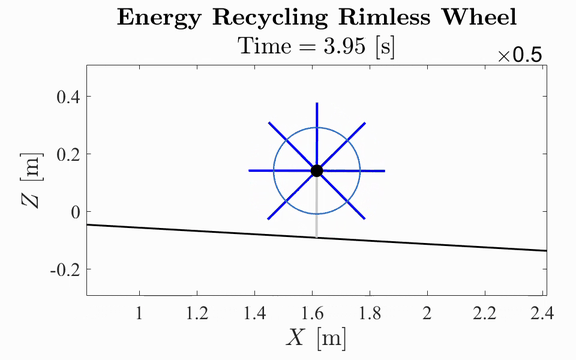
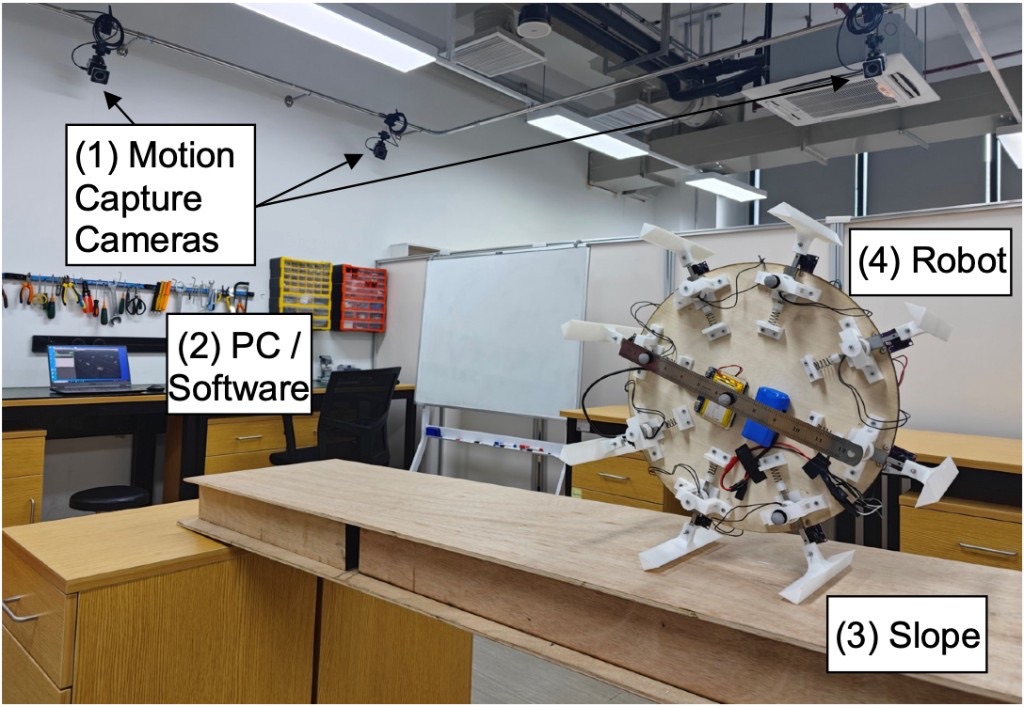
Energy-Recycling Rimless Wheel with Spring-Clutch Legs
Undergraduate Research @ Technion · 2024
Proposed a spring-clutch mechanism that stores impact-induced elastic energy after foot contact and reinjects it in the next gait cycle. Developed a hybrid dynamic model, analyzed periodic gait stability with Poincaré maps, and validated passive walking on a prototype inclined-plane setup (CoT ≈ 0.02).
* Co-authored paper under review at Robotica.
Learning & Practice Projects
-
Hopper_sim_modelbase
Model-based simulation and control framework for a hopping robot.
-
Quadrotor_dynamics_sim
Dynamics modeling and simulation of a quadrotor UAV.
-
Spring_Dynamic_sim
Dynamic simulation of spring-mass systems and related mechanisms.
-
RL_cart
Reinforcement learning implementation for the classic cart-pole balancing problem.
-
Legged_Robot_Clutch-Spring
Simulation and design of a clutch-spring energy recycling mechanism for legged robots.