Chuhan Daniel Zhang
My robotics journey began when I entered middle school VEX competitions. Translating precise algorithms into consistent physical motion taught me that reliable autonomy in robots requires careful interweaving of sensing, actuation, and control. This work sparked my desire to create agile, intelligent machines. My research in robotics has now narrowed to the core objective of enabling robots to navigate unstructured environments efficiently while being robust against disturbances. Ultimately, I aim to develop control frameworks that combine mechanical intelligence, model-based dynamics, and data-driven adaptation.
I am an M.S.E. student in Robotics (Medical Robotics track) at Johns Hopkins University. I completed my B.Sc. in Mechanical Engineering (Robotics) at Technion – Israel Institute of Technology. I have been a Research Assistant at The Chinese University of Hong Kong, working on hopping robots and real-time control.
Johns Hopkins University, Baltimore, MD
News
My Journey in Robotics
-
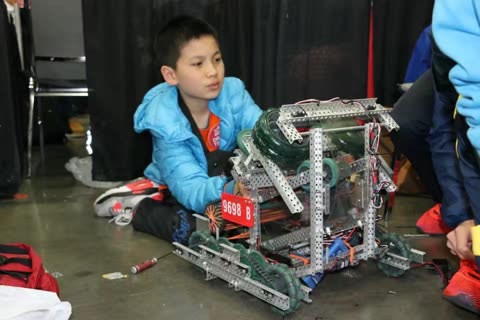 2015
VEX Team 9698B
My first competition robot; VEX Asia-Pacific Champion, Melbourne.
-
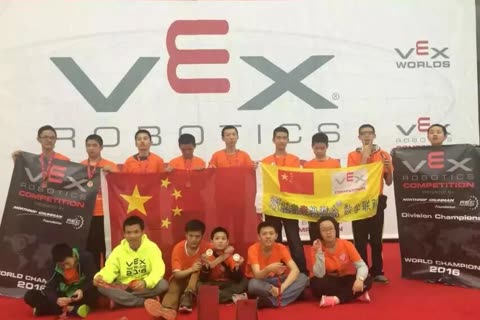 2016
VEX Worlds
Division Champion, VEX World Championship, Louisville.
-
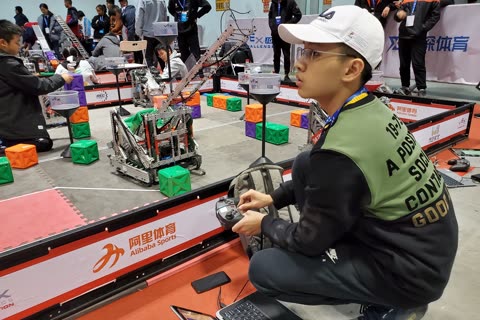 2019
VEX Team 96666A
Gold Award, VEX Asia-Pacific Championship, Seoul.
-
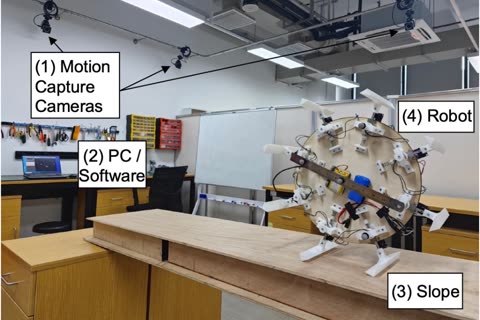 2024
Legged locomotion
First research project at Technion: an energy-recycling rimless wheel.
-
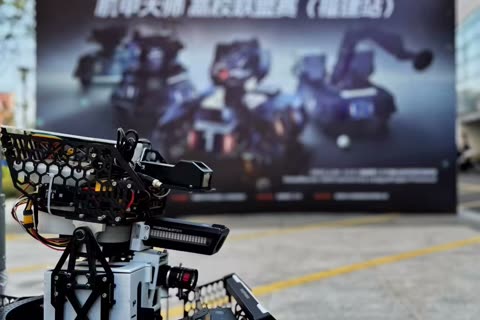 2025
RoboMaster RMUL
Second Prize with the Kongfu Team.
-
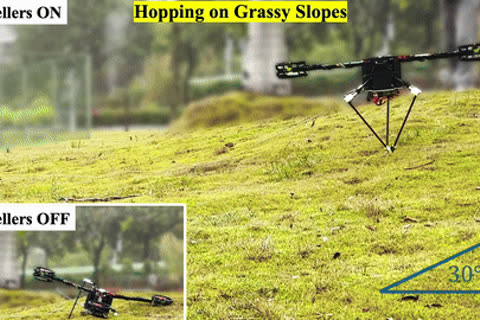 2025
Propeller-assisted hopper
Research Assistant at CUHK; IEEE CASE 2026, Best Student Paper finalist.
-
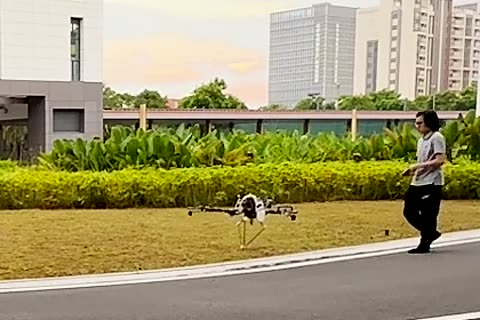 2026
Hopping mobile manipulation
A hopper that folds its arms into a wheeled mobile manipulator.
-
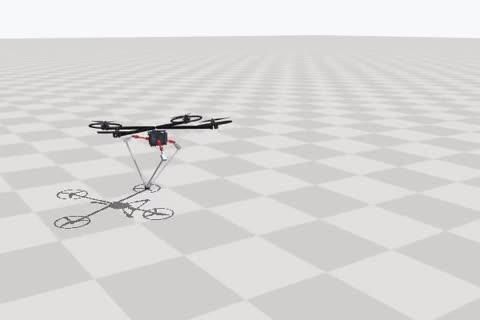 2026
LLM co-design
CoRL 2026 workshop paper: an LLM designs a hopper's leg and rotors.
-
 Now
Johns Hopkins University
M.S.E. in Robotics at LCSR.
Education
Johns Hopkins University
Technion – Israel Institute of Technology