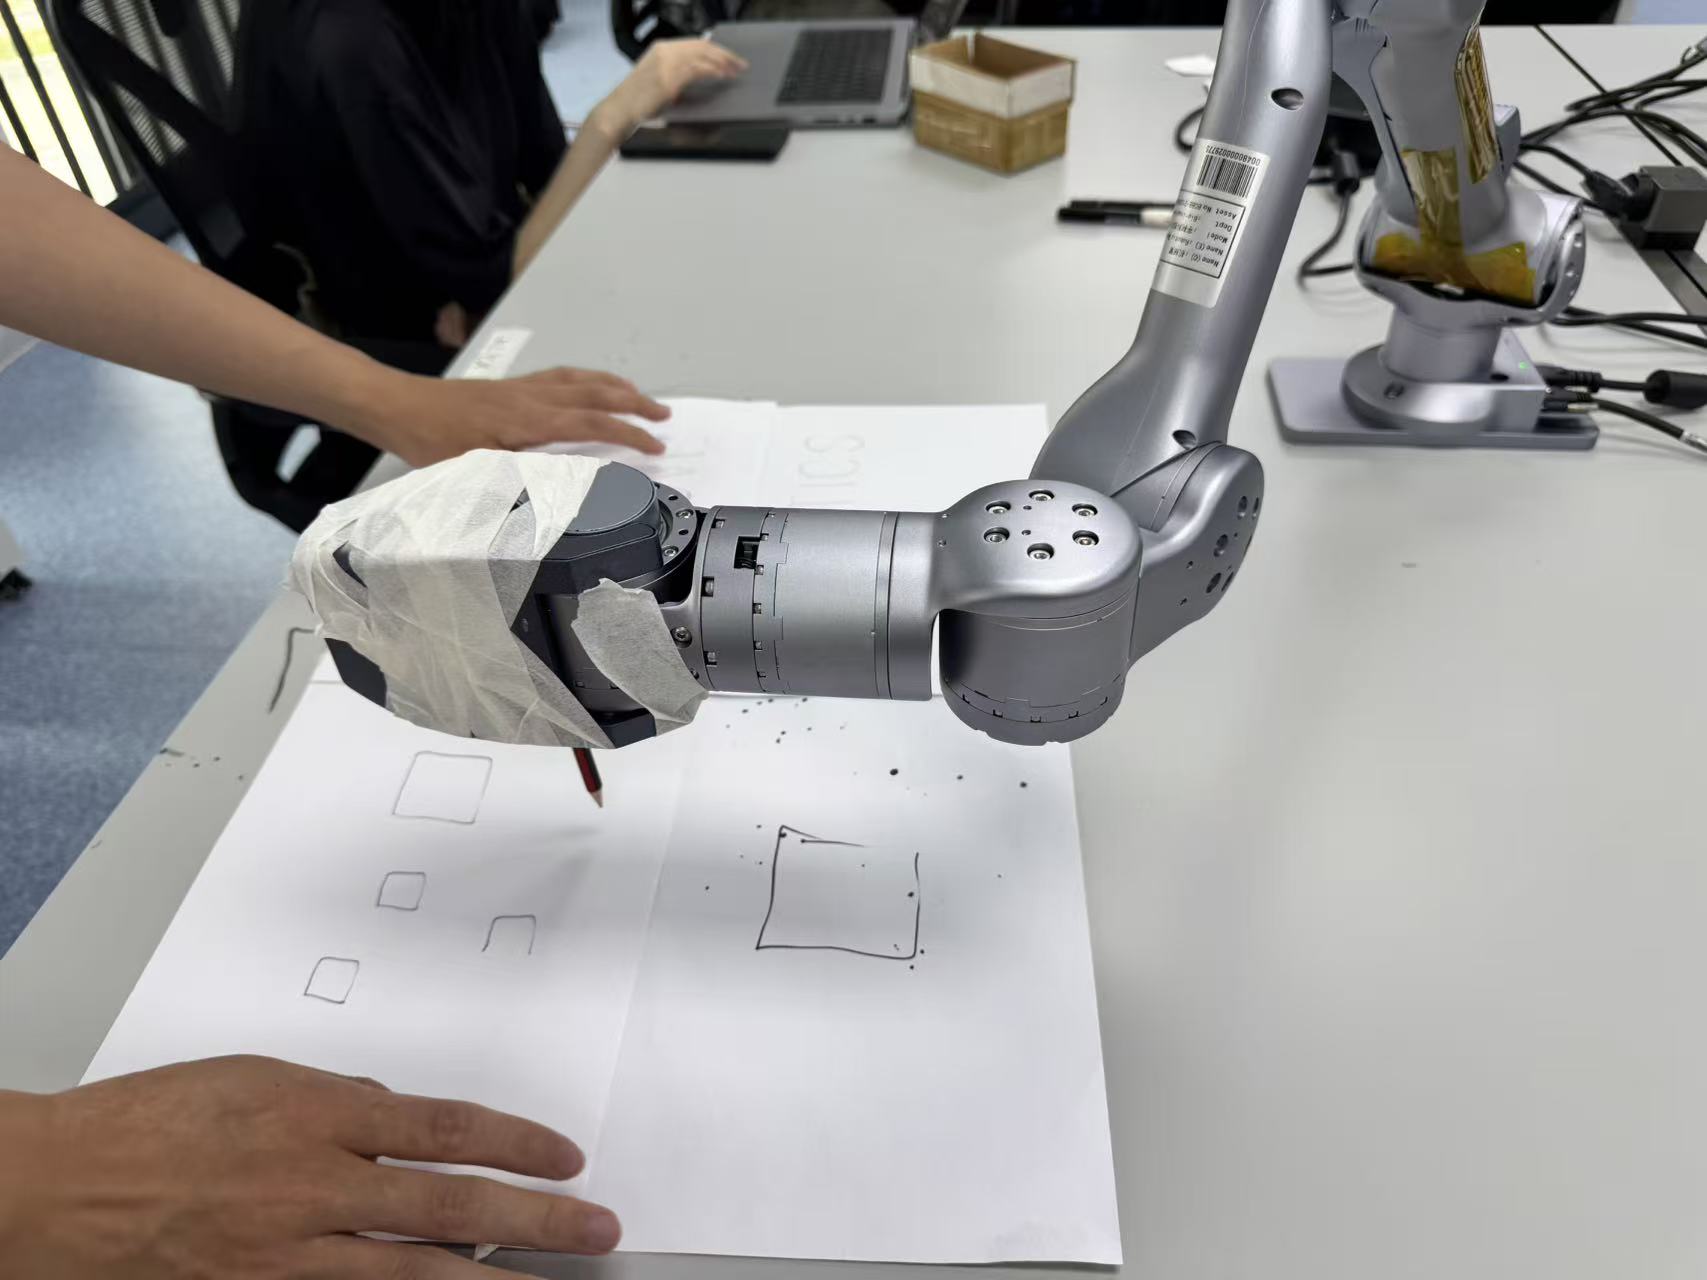
Unitree Z1 Robotic Arm
Advanced Robotics Laboratory (034401), Technion, Spring 2025
Instructor: Prof. Damiano Padovani
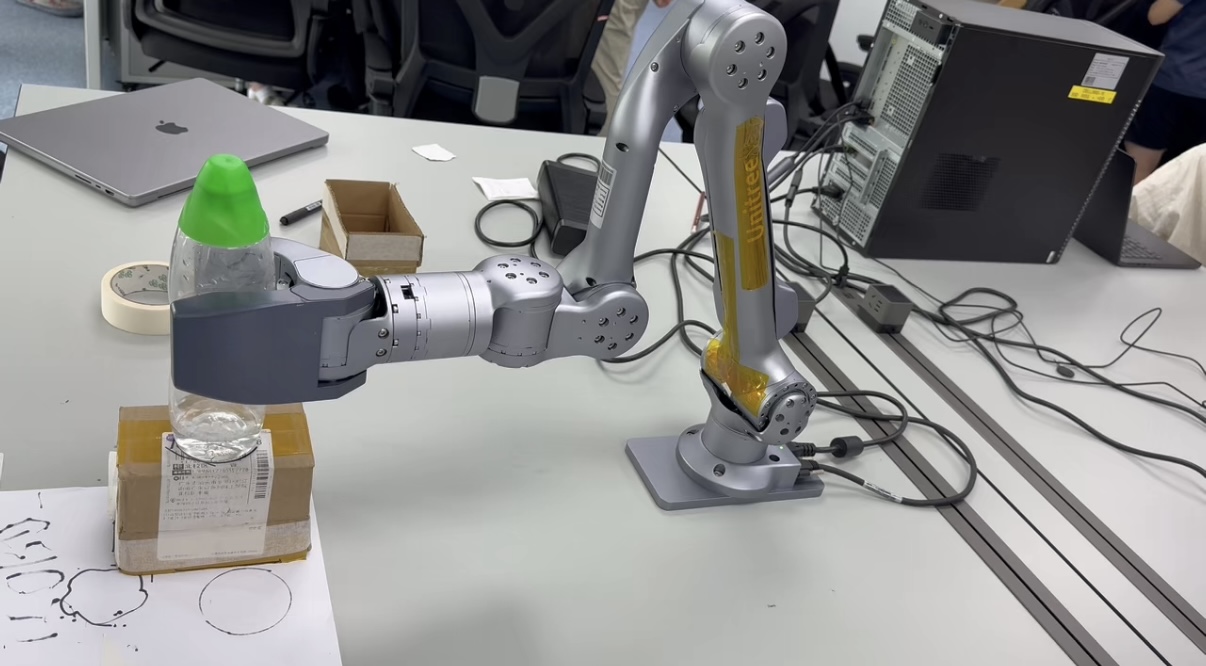
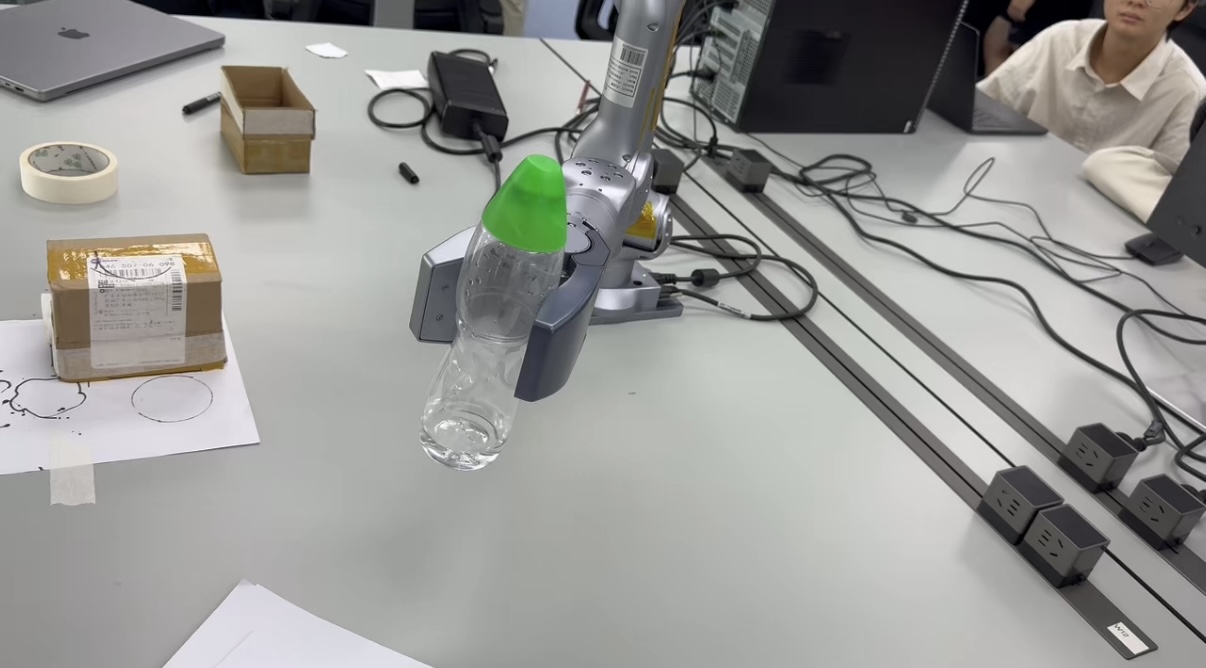
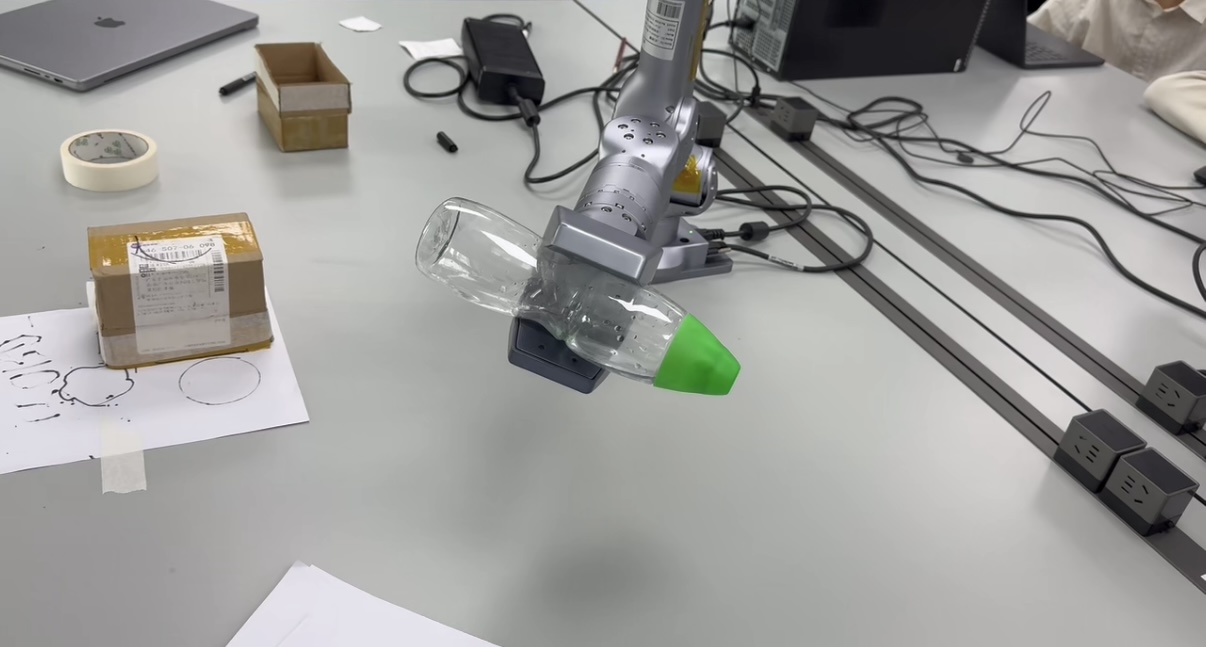
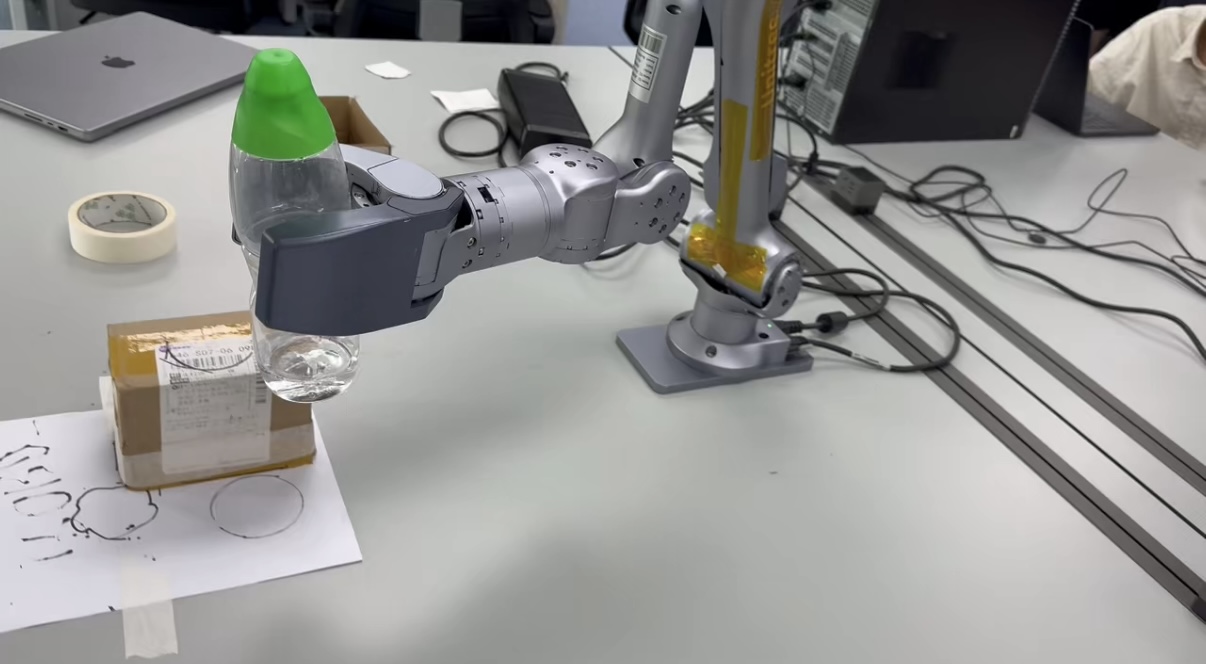
Implemented trajectory planning and pick-and-place tasks for the Unitree Z1 (6-DOF) using z1_sdk.
Technical Implementation
- SDK Setup: Configured z1_controller and z1_sdk for robot communication.
- Control Modes: Used joint-space (JOINTCTRL) and Cartesian-space (CARTESIAN) control.
- Trajectory Planning: Used polynomial trajectories for smooth motion.
- Pick-and-Place: Built task routines using MoveJ, MoveL, and MoveC.
- Drawing Task: Tracked end-effector paths for marker drawing.
- Teach & Replay: Recorded trajectories in TEACH mode and replayed them with TEACHREPEAT.