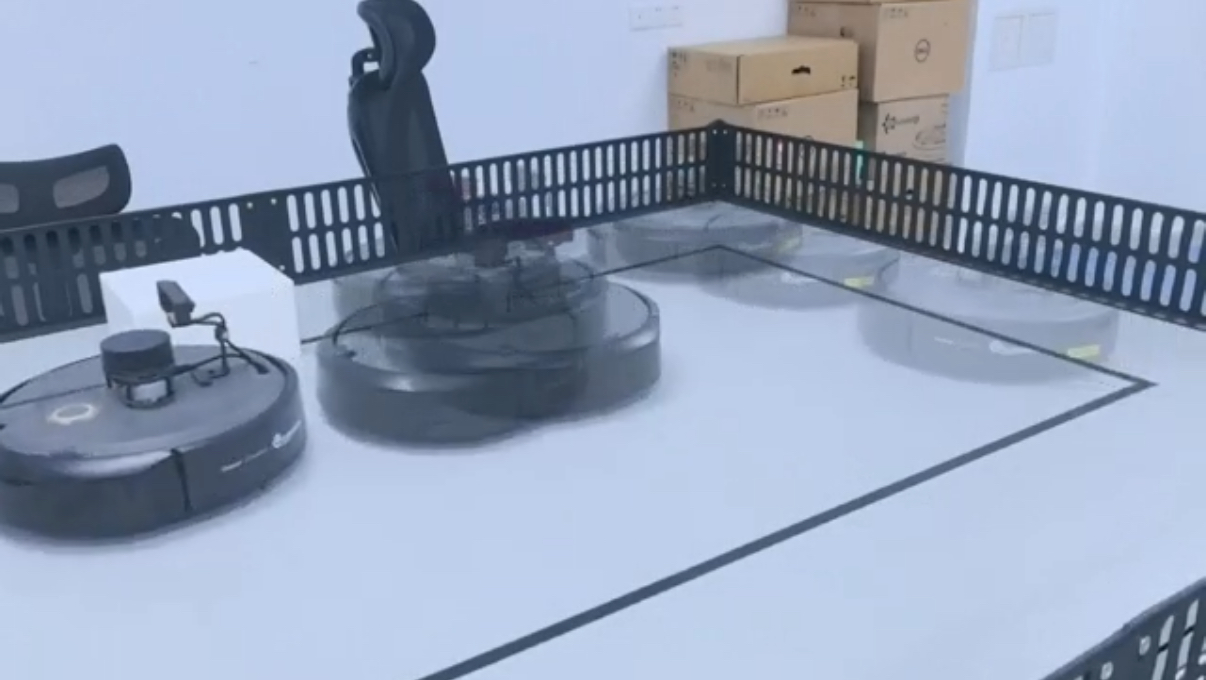
TurtleBot Autonomous Navigation
Advanced Robotics Laboratory (034401), Technion, Spring 2025
Instructor: Prof. Damiano Padovani
Built autonomous navigation and obstacle avoidance routines for TurtleBot 4 using ROS2 Humble.
Technical Implementation
- ROS2 Setup: Built a workspace with custom Python nodes for motion control.
- Teleoperation: Implemented keyboard teleop publishing Twist messages to the
cmd_veltopic. - Circular Motion: Programmed closed-loop velocity control for a target radius (~30 cm).
- Path Following: Built timer-based routines to follow a predefined path.
- Obstacle Avoidance: Used 2D LiDAR for collision detection and to go around obstacles.
- Sensors: Studied how to combine OAK-D depth camera and LiDAR for navigation.