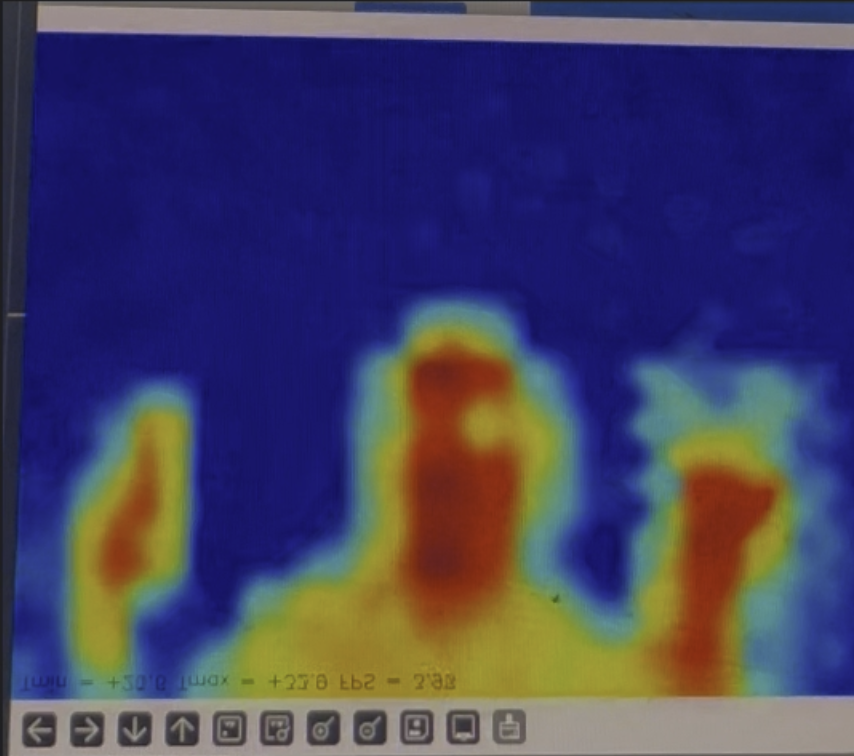
Thermal Imaging Tracking Gimbal
Course Project, Technion, 2024
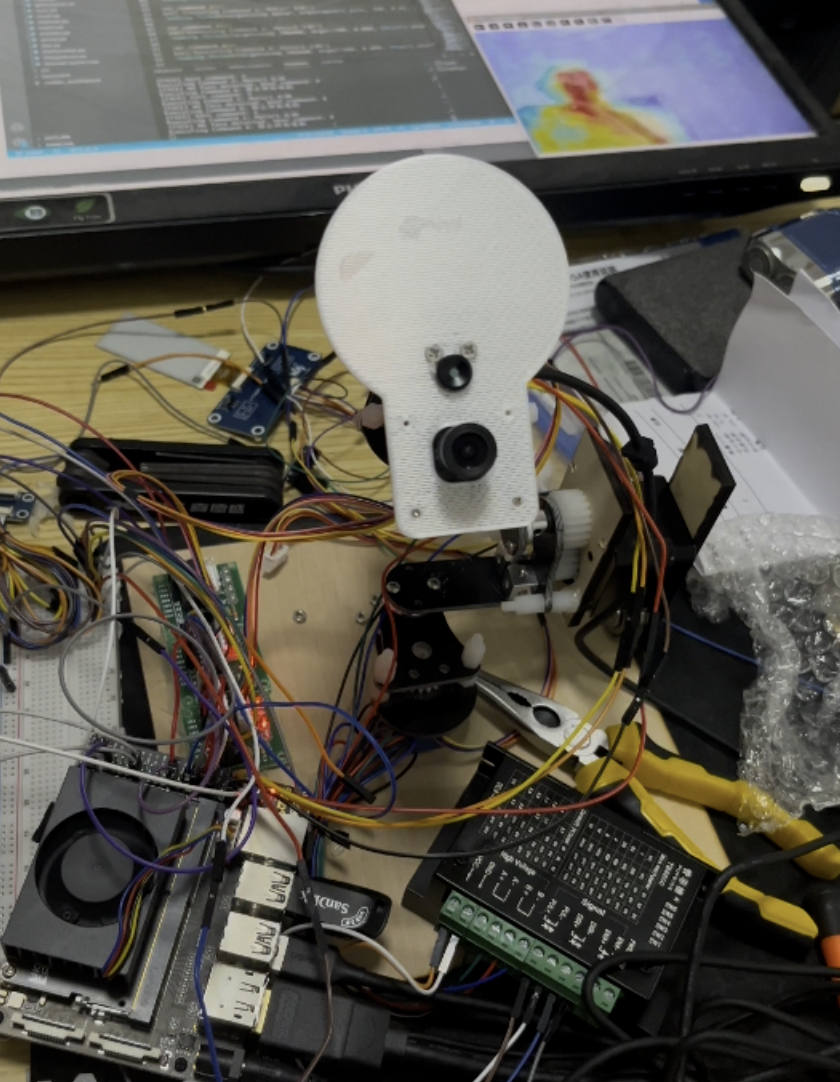
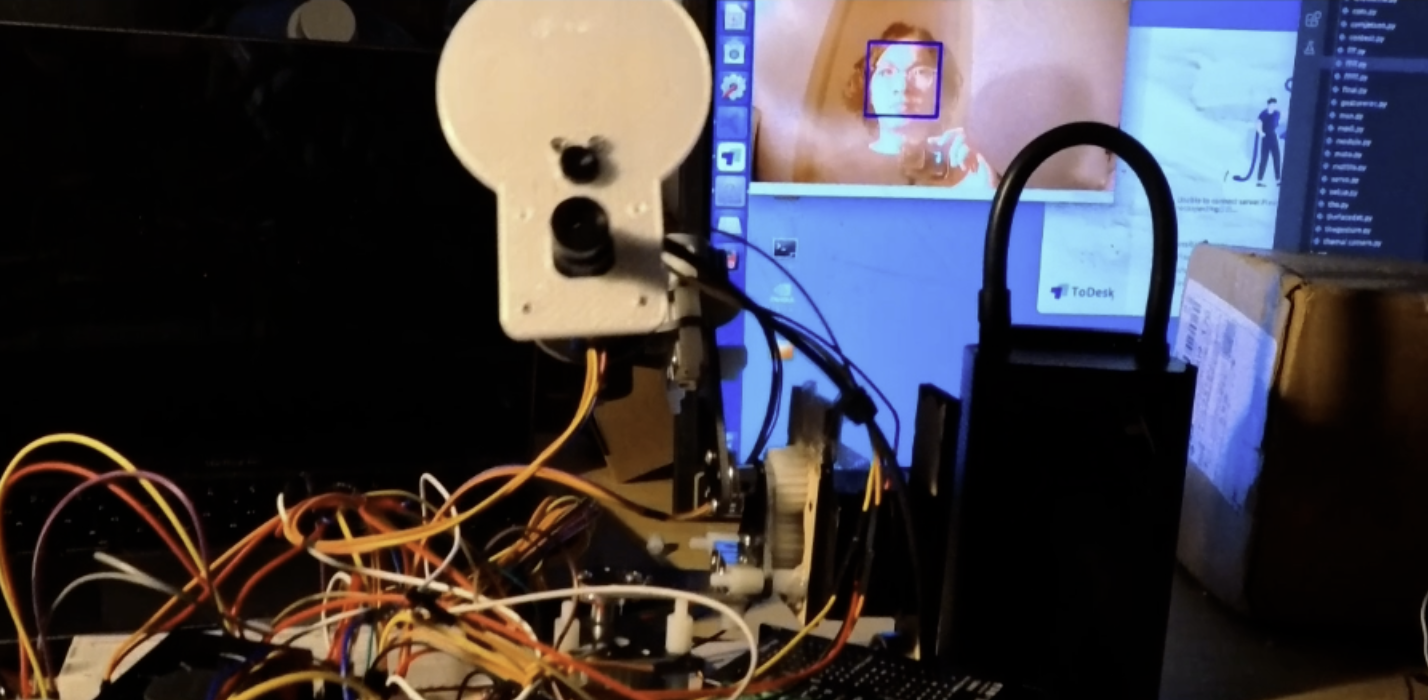
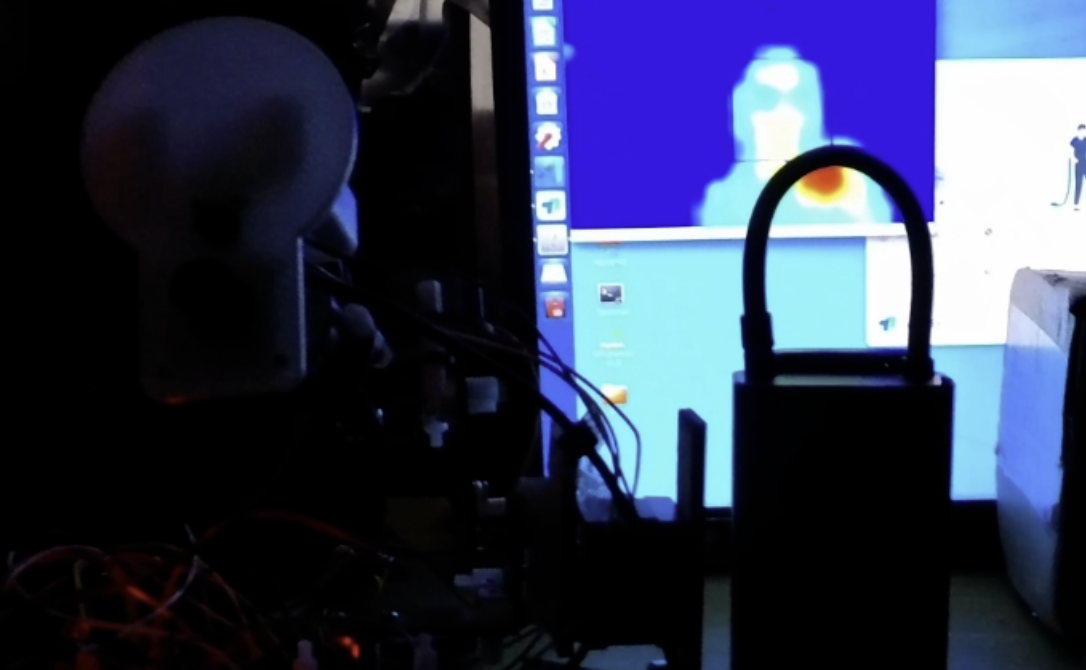
Built a tracking gimbal that combines computer vision and thermal imaging on an NVIDIA Jetson Nano.
Core Contribution
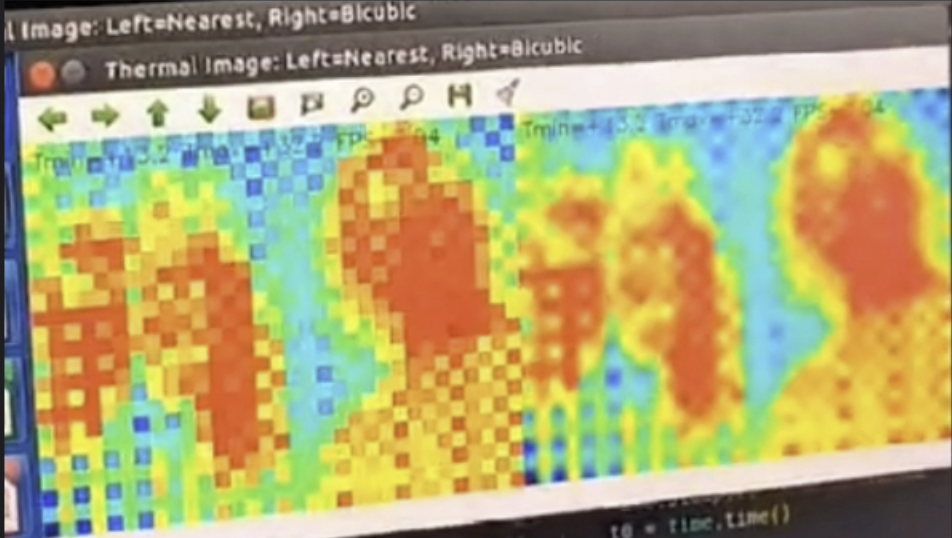
Implemented bicubic interpolation to increase the resolution of the AMG8833 thermal sensor data and generate smoother thermal maps in real time.
Aligned the RGB camera view and the thermal view by estimating a 2D mapping (image registration), enabling an overlay of thermal information on the RGB frame.
Core Hardware
- NVIDIA Jetson Nano
- Dual-Axis (Pan/Tilt) Stepper Motor Gimbal
- Webcam + AMG8833 Thermal Imaging Sensor
Features
- Face Tracking: Used OpenCV (Haar cascade) for real-time face detection and tracking.
- Meditation Mode: Detects stillness and controls ambient lighting.
- Movie Mode: Monitors movement and adjusts the environment.