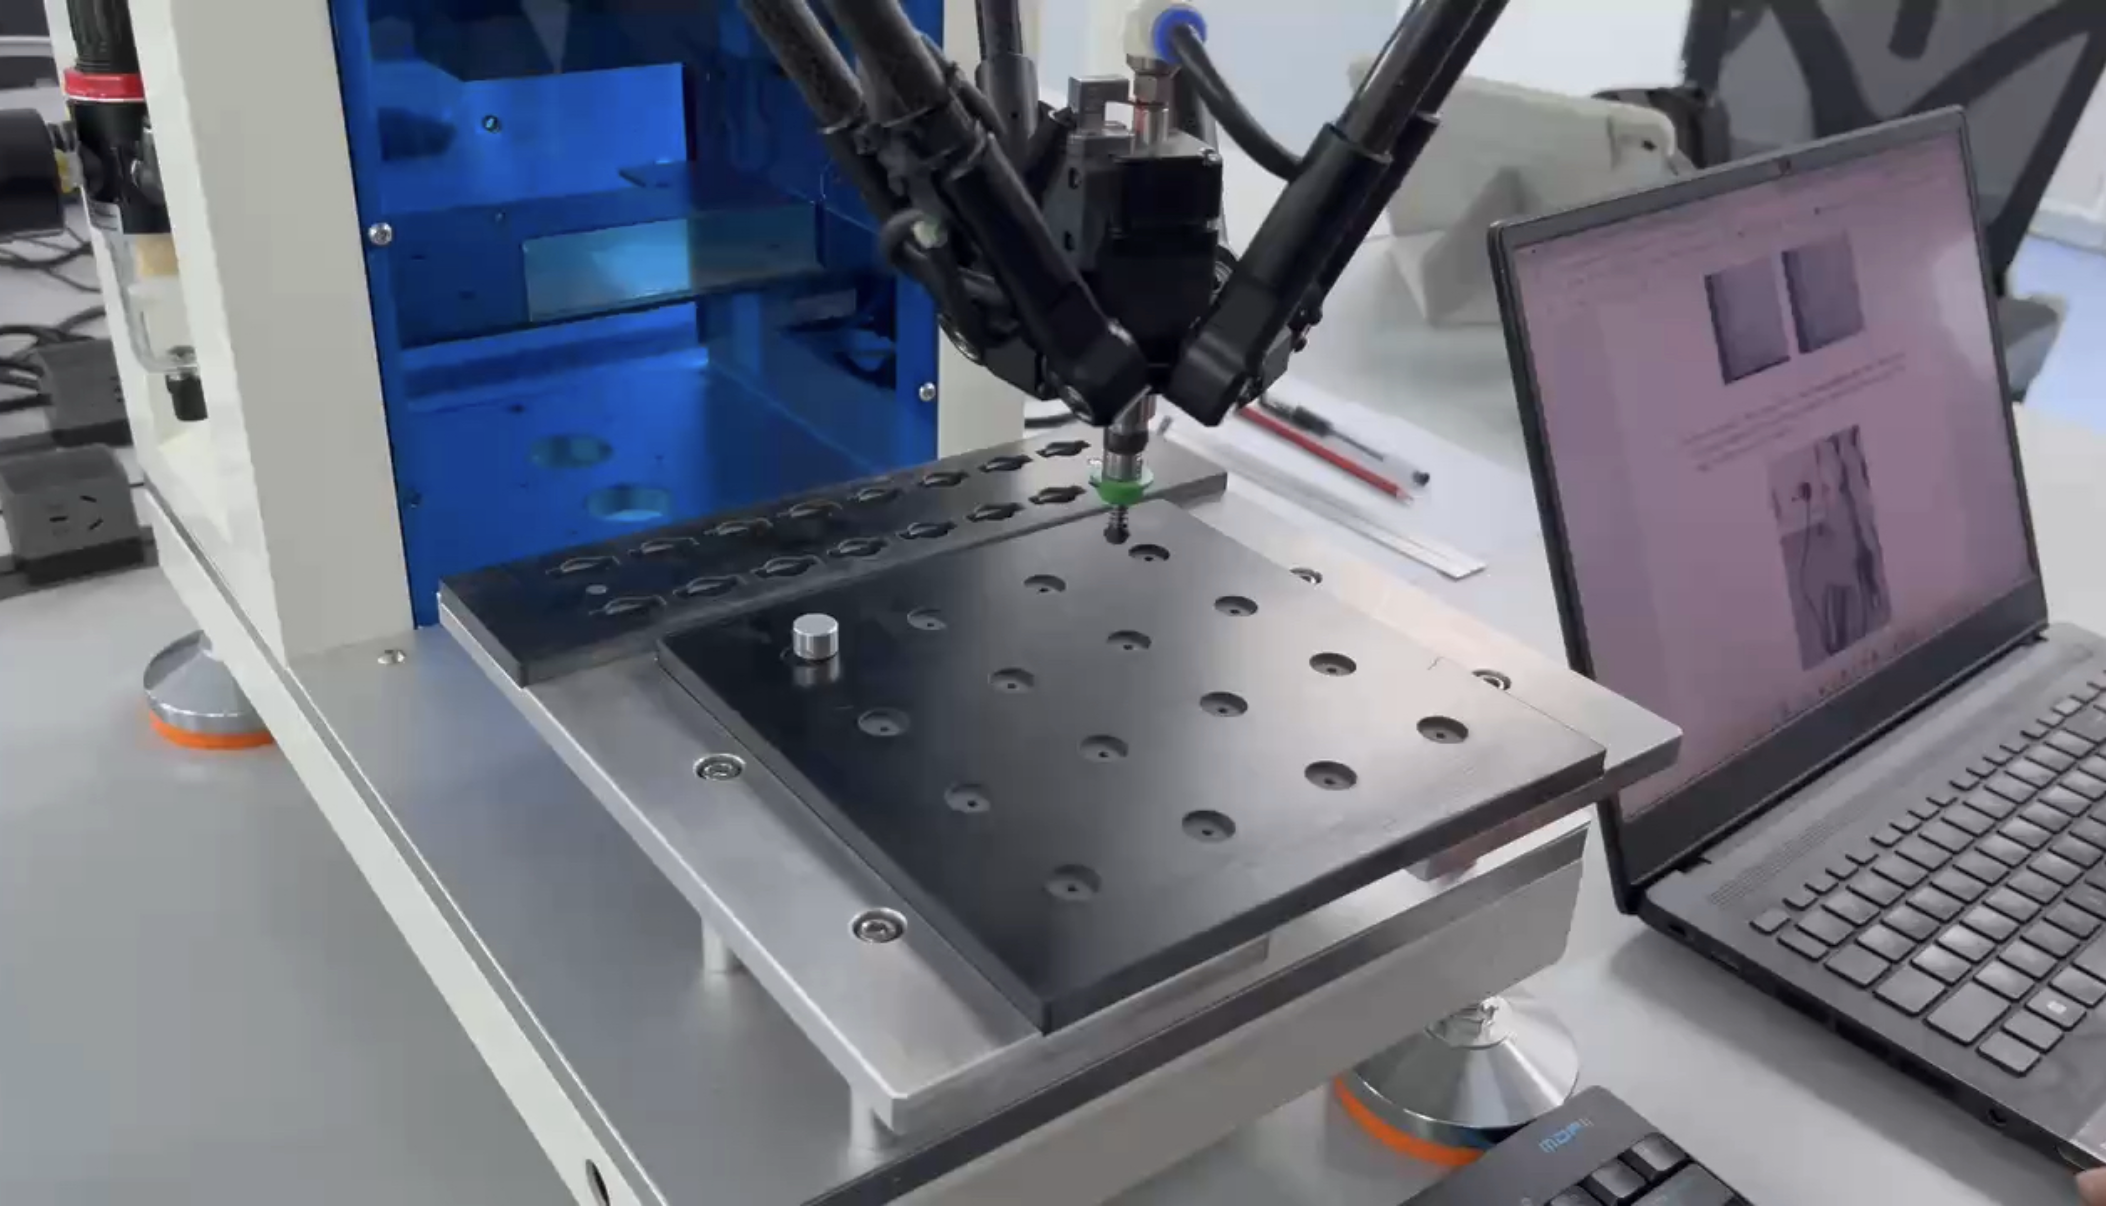
Delta Parallel Manipulator
Advanced Robotics Laboratory (034401), Technion, Spring 2025
Instructor: Prof. Damiano Padovani
Programmed an industrial GTHZ-300B Delta robot for high-speed pick-and-place tasks.
Technical Implementation
- Parallel Kinematics: Studied the 3-DOF parallel mechanism (translation in X/Y/Z only).
- Pneumatics: Set vacuum control at 4 bar for grasping.
- Motion Programming: Used MoveDoor commands for pick-and-place motion.
- I/O Timing: Used SetOutputBeforeEnd to trigger vacuum 0.01 s before reaching the target.
- Teach Mode: Captured positions with LoadPoint.
- Safety: Used AxisHome and SetFixedSpeed (50%) for safe operation.